Eugenio (Henny) Frias-Miranda
Eugenio (Henny) Frias-Miranda
Home
Research
Gallery
Publications
Contact
Light
Dark
Automatic
1
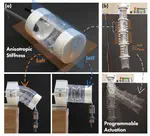
Anisotropic Stiffness and Programmable Actuation for Soft Robots Enabled by an Inflated Rotational Joint
Soft robots are known for their ability to perform tasks with great adaptability, enabled by their distributed, non-uniform stiffness …
Sicheng Wang
,
Eugenio (Henny) Frias-Miranda
,
Antonio Alvarez Valdivia
,
Laura H. Blumenschein
PDF
Cite
Video
IEEE Xplore
Adaptation and Training Effects from a Passive, Wearable Resistance Device During Exercise
The integration of technology into exercise regimens has emerged as a strategy to enhance normal human capabilities and return human …
Eugenio (Henny) Frias-Miranda
,
Hong-Anh A. Nguyen
,
Jeremy Hampton
,
Trenner A. Jones
,
Benjamin Spotts
,
Matthew Cochran
,
Deva D. Chan
,
Laura H. Blumenschein
PDF
Cite
Video
IEEE Xplore
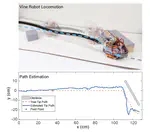
Vine Robot Localization via Collision
Localization of robots is a complex task that is often hindered by the sensors these systems use. Due to the majority of field robots …
Eugenio (Henny) Frias-Miranda
,
Alankriti Srivastava
,
Sicheng Wang
,
Laura H. Blumenschein
PDF
Cite
Video
DOI
IEEE Xplore
Cite
×